Stanford University
 Chelsea FinnCo-founder · Physical IntelligenceResearcher↗

Researcher · Academic · Founder
Sergey Levine
 Physical IntelligenceCo-founder
 UC BerkeleyAssociate Professor
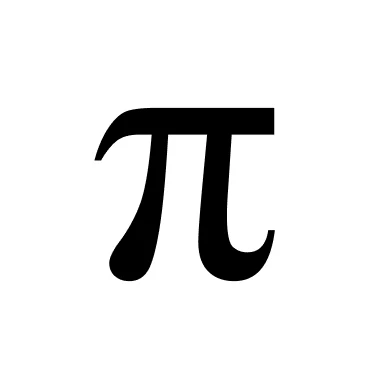
Levine helped teach robots to grasp unfamiliar objects by learning from hundreds of thousands of attempts.[1] He co-developed Soft Actor-Critic, a method for learning actions through trial and error,[2] and π0, a general-purpose robot model that follows instructions to perform tasks such as folding laundry.[3]
Career & education
Current rolesPhysical Intelligence2024-presentCo-founderUC Berkeley2021-presentAssociate Professor
Physical Intelligence2024-presentUC Berkeley2021-presentPreviouslyUC Berkeley2016-2021Assistant Professor
UC Berkeley2016-2021Education
Work and education history is primarily focused on AI-relevant roles and may not be comprehensive.
Citation Trend
Total citations to scholarly work, including research papers, technical reports, books and theses, as recorded by Google Scholar. Each point is a dated snapshot.
citations296,999As of Nov 1, '26
citations+13,685Since last snapshot, Oct 1, '26
Selected contributions
Model-Agnostic Meta-Learning for Fast Adaptation of Deep Networks
With Chelsea Finn and Pieter AbbeelMAML trains models to adapt to new tasks with only a few examples.
References
- Learning Hand-Eye Coordination for Robotic Grasping with Deep Learning and Large-Scale Data Collectionarxiv.org
Levine first-authored work learning grasping from over 800,000 attempts, including successful grasps of novel objects.
- Soft Actor-Criticarxiv.org
Levine co-authored the Soft Actor-Critic reinforcement-learning algorithm for continuous control.
- π0: A Vision-Language-Action Flow Model for General Robot Controlarxiv.org
Levine co-authored generalist robot model following language instructions, including laundry folding.
Based on public sources. If accuracy is important, verify details using the links or references.
For corrections, updates, or requests to remove information, contact us.
Reviewed July 23, 2026 · Checked for accuracy and new information.